{{ variable.name }}
| Type | Portable Micro AUV /Easy-launch Micro AUV | Model | AUV-160 |
| Params | Dimensions160 mm × 1.8 m; 35 kg (payload 5 kg); Depth 0–100 m; Speed 1–5 knots; Endurance ≥8 h @ 3 knots; Navigation INS+DVL+GNSS | Scope | portable micro AUV system, shore launch, small-boat deploy-ment, and net recovery |
| Material | lightweight aluminum frame, seawater-resistant polymer casing, corrosion-resistant components, pressure-sealed electronic pod | Applicable Industry | Education & Practical Training; Payload Integration & Testing; Multi-Vehicle Cooperative Testing; Ocean Environmental Monitoring; Aquaculture Monitoring & Inspection; Water Area Security Surveillance |
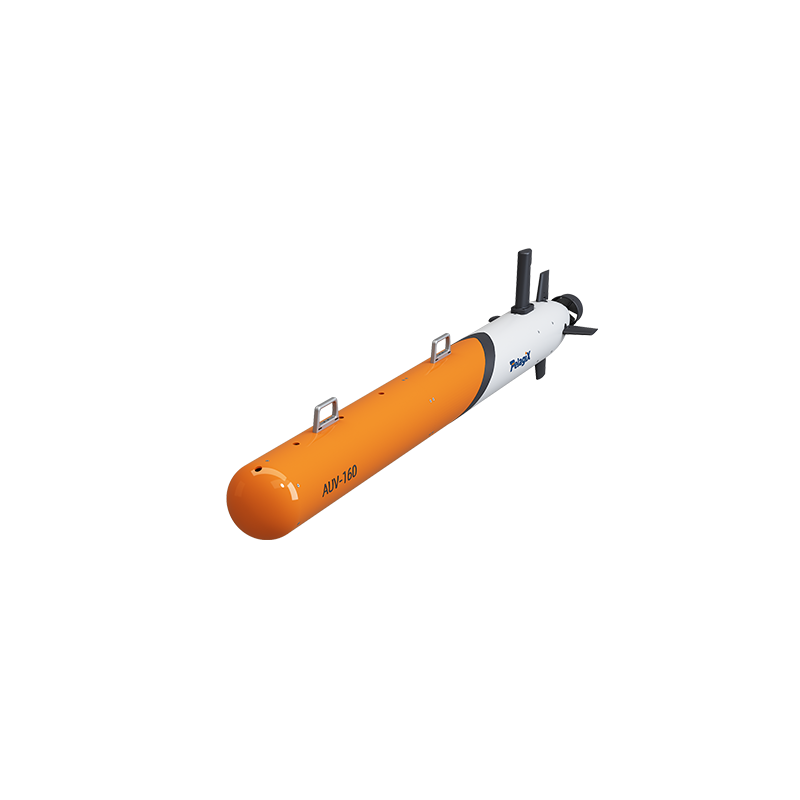
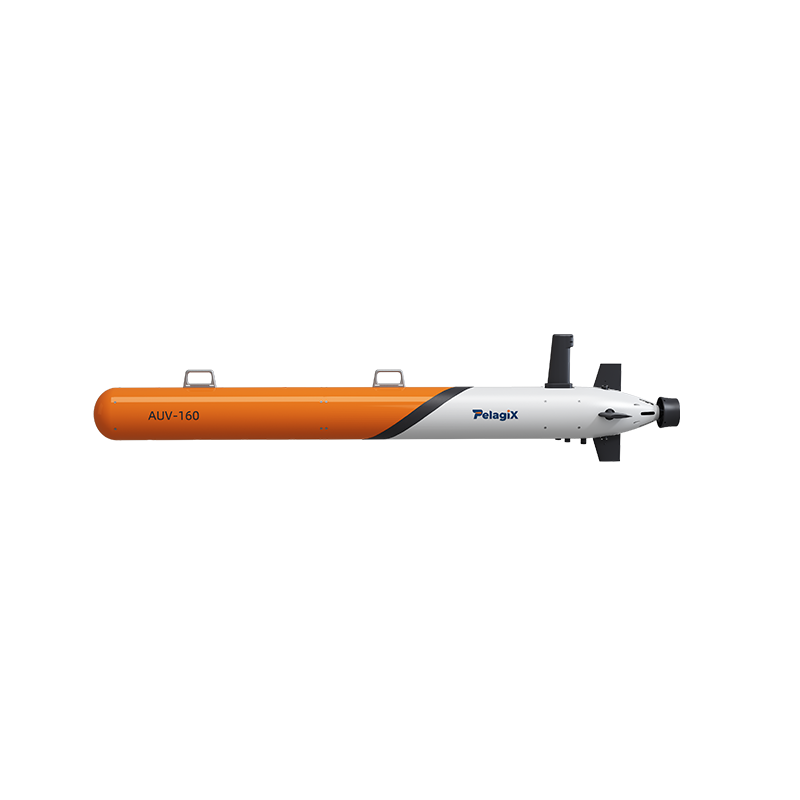
This AUV-160 portable micro autonomous underwater vehicle adopts a lightweight aluminum frame, supporting shore launch and small-boat deployment with convenient deployment and recovery. Built with seawater-resistant polymer housing and corrosion-resistant components plus a pressure-sealed electronic pod, it delivers reliable performance in marine environments. It features compact dimensions of 160 mm × 1.8 m, total weight of 35 kg and a 5 kg payload capacity, capable of operating at depths from 0 to 100 m, cruising at 1–5 knots with endurance over 8 hours at 3 knots. Powered by the integrated INS+DVL+GNSS navigation system, it achieves precise positioning even in GPS-denied underwater environments. It serves multiple scenarios including education & practical training, payload integration & testing, multi-vehicle cooperative testing, ocean environmental monitoring, underwater mapping, aquaculture survey and security surveillance.

Autonomous Underwater Vehicle (AUV)-160-1

Autonomous Underwater Vehicle (AUV)-160